A multidisciplinary body of research converging on field-coupled, trans-medium mobility
The NRGscapes LAB archive contains a broad body of observational, theoretical, technical and exploratory work. This page reorganises that archive into six interacting research domains that collectively support the investigation of an unmanned fieldcraft demonstrator.
Five years inside the orb phenomenon
How does a recorded light become a scientific question—and where can that question lead?
This illustrated feature follows more than five years of NRGscapes LAB research into orb and orb-like phenomena. From Perth and Pilbara imagery to physical models, biomimetic materials and conceptual craft architectures, it traces the connections between observations, published papers and proposed experiments. Explore the images, ideas and engineering questions behind an evolving research programme.
Download the illustrated article
PDF of PowerPoint Slide Show here…

The six research domains are:
- Observational evidence
- Field physics and mechanisms
- Materials and enabling technologies
- Craft architecture and control
- Testing, validation and methodology
- Applications and future interfaces
All domains converge on the integrated goal:
An unmanned fieldcraft with boundary-coupled mobility across multiple environments.
What this page brings together
- The full report archive
- Document relationships
- Evidence tiers
- Report clusters
- Stakeholder reading pathways
- Portfolio contribution to engineering development
- Cross-domain dependencies
Key message: he portfolio is not a flat list of publications. It is an integrated body of intelligence, models, enabling technologies, architectures and validation pathways directed toward a shared engineering objective.
Portfolio integration flow:
- Observe –
- Model –
- Materialise –
- Test and validate –
- Demonstrate –
- Deploy and explore
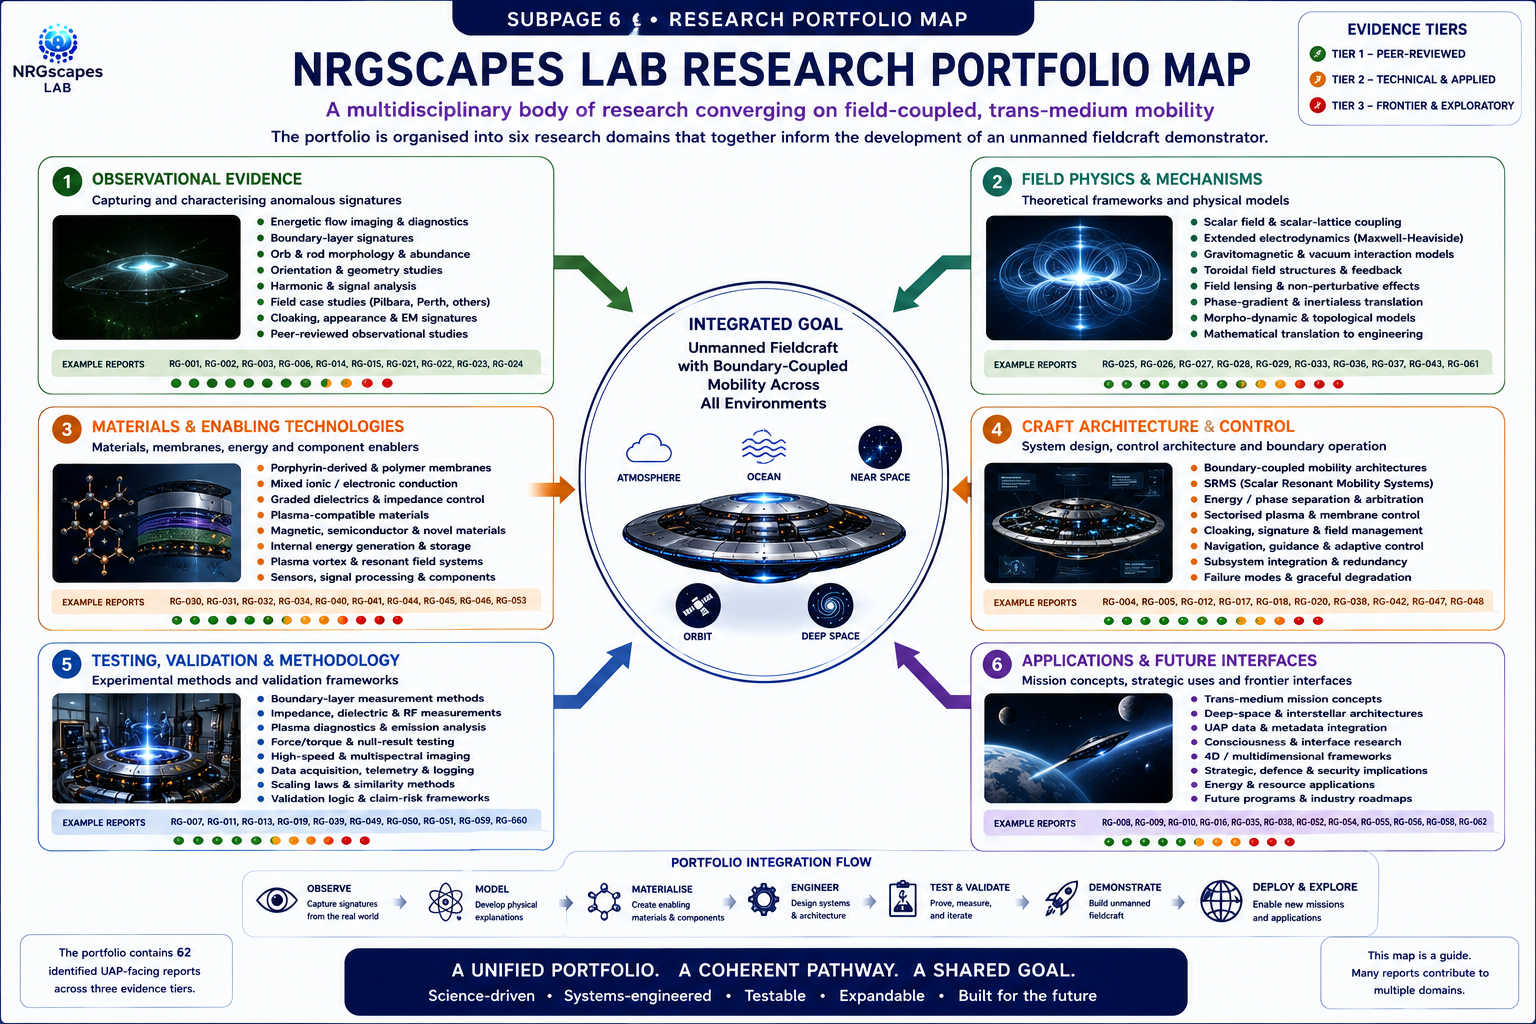
Conceptual engineering synthesis for investigation and stakeholder engagement. The architectures and pathways shown do not represent a demonstrated vehicle or operational capability.